Accelerometer or Gyroscope: Two Different Clues to Motion
An accelerometer or gyroscope answers a different motion question. Learn what each senses, how devices combine them, and where their clues stop.
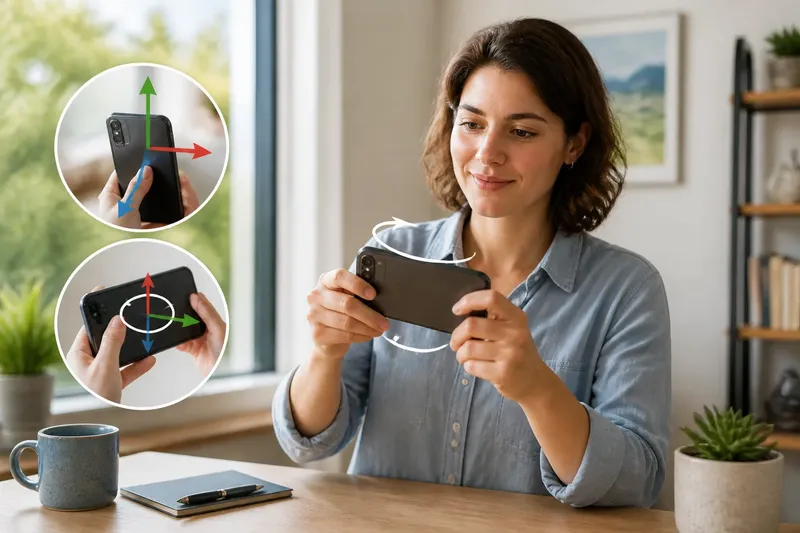
If you are choosing between an accelerometer or gyroscope, start by asking what motion you need to know about: a change in speed or direction, or a turn around an axis. An accelerometer senses acceleration, while a gyroscope senses rotation; neither gives a complete account of how a device traveled or what caused it to move.
That distinction matters when you interpret a phone’s screen rotation, a game controller’s gestures, or a small robot’s movement. Follow the clues in order: identify the motion, read what the sensor reports, then consider what the signal can and cannot tell you.
What question are you trying to answer?
Motion is not one signal. A device can speed up, slow down, turn, tilt, vibrate, or remain still while its orientation changes relative to the room. Those events overlap, but they are not interchangeable.
Use an accelerometer when the useful clue is a change in velocity along one or more directions. Use a gyroscope when the useful clue is angular motion: how quickly the device is turning around an axis. A device that needs a richer motion estimate may use both, but combining them does not remove uncertainty.
- Acceleration: a change in velocity, including speeding up, slowing down, or changing direction.
- Rotation: a change in orientation, described as turning around an axis.
- Position: where the device is in space. Neither sensor directly reports this.
Before comparing sensor readings, be precise about the question. “Did the phone tilt?” is different from “Did it move across the table?” A tilt can happen without a large shift in position, and movement across a surface can happen without a noticeable turn.
What does an accelerometer reveal?
An accelerometer reports acceleration along the sensor’s axes. In a phone, those axes are tied to the device itself, not permanently to the room. Rotate the phone and the direction represented by an axis rotates with it.
Gravity is part of the signal. When the device is at rest, gravity still exerts an effect that the accelerometer senses, so the reading can help distinguish an orientation such as lying flat from standing upright. But a reading that includes gravity is not a simple label saying “tilted” or “moving.”
Motion complicates interpretation. If you push a phone forward while also tilting it, the measured acceleration reflects the combined effects of the device’s movement and gravity. Software can estimate and separate components, but that estimate depends on assumptions and other information.
Accelerometers are useful for detecting events such as a bump, a shake, or a change in direction. They can also help a device decide whether its orientation has changed enough to rearrange a display. They do not, by themselves, tell you the path the phone followed or the distance it traveled.
What does a gyroscope reveal?
A gyroscope in an electronic device reports angular velocity: how quickly it rotates around its axes. Its signal is especially useful for following turns and quick changes in orientation, including when the device is moving at the same time.
That makes a gyroscope a helpful partner for a game that responds to steering gestures or a camera interface that needs to track a phone’s rotation. The sensor can report a turn even when the accelerometer’s readings are hard to interpret because several forces are mixed together.
A gyroscope does not directly announce the device’s final orientation. Software can integrate its rotation readings over time to estimate how orientation changes, but small errors can accumulate. Without a reliable reference to correct that drift, the estimate may gradually depart from the device’s actual orientation.
Nor does a gyroscope tell you that the device moved from one place to another. A phone can rotate in someone’s hand while staying roughly in place, or travel across a room without rotating much. Rotation is a useful clue about movement, not a map of the device’s route.
How should you compare their signals?
Think of each sensor as answering a different question. An accelerometer says how acceleration is changing along its axes; a gyroscope says how quickly the device is turning. The readings have different units and meanings, so one cannot simply stand in for the other.
Imagine a phone resting on a desk, then being lifted and turned toward a window. Its accelerometer registers the changing influence of gravity and the acceleration involved in lifting it. Its gyroscope registers the turn. Neither reading alone gives a full description of the hand’s path or the phone’s position relative to the desk.
For a basic orientation feature, a device may use the accelerometer to estimate which way gravity points and use that estimate to set the screen layout. For a responsive motion control, it may use gyroscope data to follow quick turns, with acceleration data helping provide context. The exact division of work depends on the device and its software.
When you inspect a sensor app, look for the sensor name, axis labels, and units before drawing conclusions. A changing value is not automatically proof that the device traveled in that direction: the sensor axes move with the device, and the reading may include gravity or other motion.
How does sensor fusion help?
Sensor fusion combines readings to produce a more useful estimate than either signal offers alone. A phone can compare the accelerometer’s gravity-related clue with the gyroscope’s short-term account of rotation. Software then uses the two to estimate orientation while accounting for the strengths and weaknesses of each.
The gyroscope can follow rapid turns smoothly, while the accelerometer can provide a reference related to gravity. In a typical orientation estimate, that reference can help correct gradual gyro drift. But acceleration caused by a shove or vibration can make the accelerometer’s gravity clue less clear, so software must judge how much weight to give it.
Fusion does not mean the device has learned every detail of its movement. The estimate may still lack a dependable position reference, and errors can enter through sensor noise, calibration, or the assumptions in the software. A screen that rotates correctly is evidence that the system has enough information for that task, not proof that it can reconstruct a full journey.
Which sensor answers common motion questions?
Can an accelerometer detect tilt?
It can help estimate tilt when the device is still or moving gently, because gravity contributes to its readings. During strong movement, the signal combines gravity with acceleration, making tilt harder to infer from that sensor alone.
Can a gyroscope tell where a phone is?
No. It reports rotation rate, and software can use that signal to estimate orientation changes over time. Position requires other information or a suitable reference beyond the gyroscope’s readings.
Why does a phone use both sensors?
The sensors provide complementary clues: one reports acceleration and the other reports rotation. Combining them can support a steadier orientation estimate than relying on either alone, while still leaving limits in place.
Can either sensor identify what caused a movement?
Not by itself. Similar readings can arise from different actions, such as a hand turning a phone or a device being moved by an external force; software needs context to interpret them.
What can the readings not tell you?
Neither sensor directly measures location. To estimate a route from acceleration, software would need to process readings over time, and small errors can build into a large position error. A gyroscope’s accumulated rotation estimate can also drift.
Both sensors have practical limits. Vibration, sudden impacts, noisy readings, calibration, and the orientation of the sensor inside the device can affect interpretation. A sensor app may show raw or processed values, so two displays can present the same underlying motion differently.
Use the manufacturer’s description or the sensor app’s documentation to confirm which axes and units it displays. That matters when comparing readings across devices, because axis conventions and data processing can differ.
When an app labels a movement as a “turn,” “shake,” or “tilt,” treat that label as a software interpretation of sensor signals, not a direct observation of intent. The useful question is whether the interpretation is good enough for the task, such as rotating a screen or controlling a game.
How do you choose the right clue?
Start with the behavior you want to detect, then match it to the signal. For a bump or a change in linear motion, consider acceleration. For a quick turn or rotation-sensitive control, consider angular motion. If the feature needs a stable orientation estimate, it may benefit from both sensors and software that combines their readings.
Say you are prototyping a handheld game that should respond when a player turns a phone. Begin by checking whether a gyroscope is available, since rotation is the central clue. If the game also needs to distinguish a sharp jolt from a smooth turn, accelerometer data can add context; the visible result should be a control that responds to turns without treating every bump as steering.
For a simple screen-orientation feature, an accelerometer may provide enough information to infer the direction of gravity when the phone is held still. If the display needs to track orientation smoothly during continuous movement, a gyroscope can contribute faster rotation updates. In either case, judge the feature by the behavior it needs, not by assuming that one sensor knows the device’s complete motion.
The practical choice between an accelerometer or gyroscope is therefore about the clue your application needs, not which sensor is universally better. Acceleration describes changes in velocity; rotation describes turning. When you keep those questions separate, it becomes easier to understand what a device can infer—and what remains unknown.